01 · Main format
Internship
Join the complete 2–3-month engineering cycle, work within a group and take ownership of an agreed area.
Join a focused engineering cycle as an intern, project collaborator or open-source contributor. Work on a real ROS 2 platform, produce visible results and help prepare OpenAMRobot 2.0.
We received around 80 applications with excellent CVs and cover letters, and we were genuinely impressed by the quality and diversity of the candidates. We decided to invite all applicants to Step 2.
We are excited to continue the communication and learn not only about your previous experience, but also how you think, what you would improve and where you believe you can contribute most effectively.
Navigation, Blockly, missions, robot monitoring and system information from a unified browser interface. Explore the UI repository →
Hugging Face shows how an open technology community can create visible, verifiable work and build lasting value. Open source does not guarantee success - but it gives contributors the opportunity to help shape a project from its early foundation.
OpenAMRobot is already gaining traction. A successful Release 2.0 will make the project more complete, valuable, visible and easier to adopt.
Read NVIDIA’s announcement →
Join the complete 2–3-month engineering cycle, work within a group and take ownership of an agreed area.
Deliver a defined technical work package with agreed interfaces, reviews, tests and documentation.
Contribute through GitHub at your own pace while following the same engineering, documentation and review standards.
The internship is our primary format. Project collaboration and open-source contribution are optional alternatives. All formats follow one shared plan and integrate into the same release.
The philosophy of this call is unpaid contribution. These opportunities are intended for people who see clear professional value in public portfolio work, real ROS 2 and robotics experience, visible GitHub contributions and international engineering collaboration.
At the same time, paid cooperation is possible for selected candidates - particularly senior or highly specialized contributors - where their expertise and skills match a concrete project need. In some cases, this may become relevant from the second month of cooperation. This is evaluated individually and is not a guaranteed outcome of participation.
Successful participation can create a real opportunity to continue with OpenAMRobot on a long-term basis. Depending on contribution, role, project needs and available resources, this may include ongoing paid or unpaid cooperation.
For contributors who become important to the project on a long-term basis, there may also be an opportunity to discuss participation in the project through an equity arrangement structured with a vesting and cliff mechanism. Depending on the role and circumstances, such long-term cooperation may be paid, contribution-based, or combine both approaches.
These possibilities are not promises of employment, compensation or equity. Any paid or equity-based cooperation would be discussed individually and formalized through a separate agreement.
Please participate only if you can realistically commit to the scope and schedule you propose. Once you accept a work package, you are expected to drive it to an agreed, tested and documented result. If circumstances change, communicate early and prepare a responsible handover.
We work documentation-first: understand the current system, define interfaces and acceptance criteria, build, test, review and document.
We value ownership, focused communication, independent research and constructive technical disagreement.
The robot and workshop are located at MotionLab Berlin . Remote contributors work with documented interfaces, simulation and reproducible environments. Hardware results are validated in the lab.
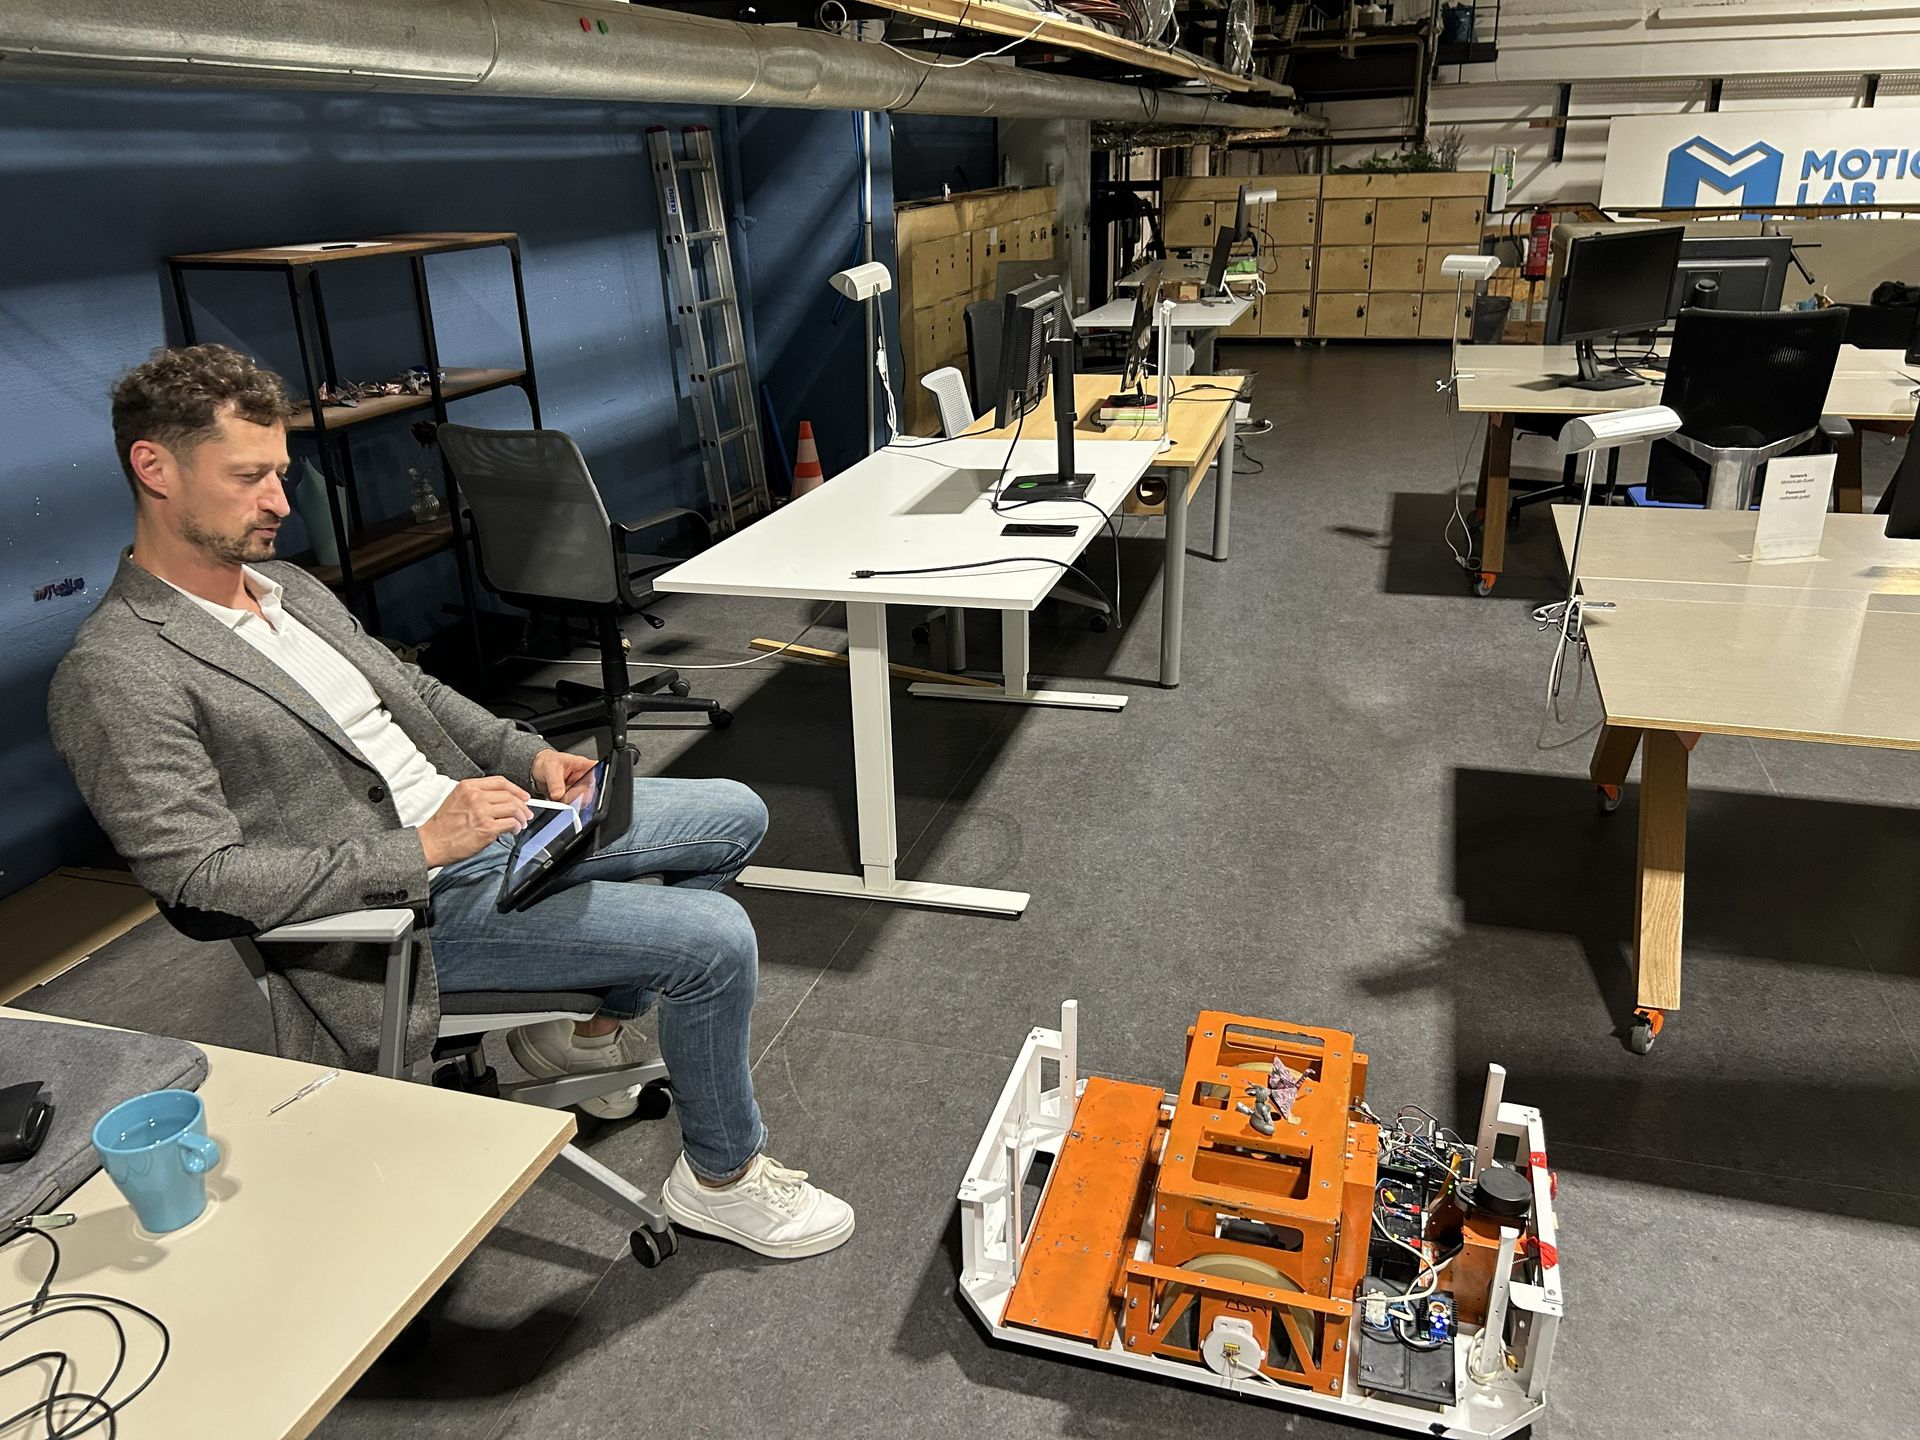
The current platform supports autonomous movement and automatic docking. Release 2.0 will strengthen integration, testing and release quality around these capabilities.
ROS 2 Jazzy, Nav2, SLAM/localization, Behavior Trees, route and zone configuration, docking, mission execution, recovery and integration testing.
OpenArm, URDF/xacro, MoveIt 2, ros2_control, grippers, drivers, Device Packages, manipulation APIs and contact/compliant motion.
LeRobot, teleoperation and demonstration capture, imitation learning, ACT, SmolVLA, dataset quality, policy evaluation, correction and deployment.
NVIDIA Jetson, Teensy/STM32, CAN/CAN-FD/CANopen, drivetrain, power and safety, sensors, wiring, mechanical integration and commissioning.
RGB/RGB-D cameras, calibration and synchronization, object perception and pose estimation, localization, sensor fusion and edge inference.
React, Flask, missions, operator and recovery UI, manipulation and training workflows, Blockly, structured voice commands, controls and diagnostics.
GitHub Actions, builds, linting, automated tests, simulation regression, containers, release artifacts, GitHub Pages, onboarding and reproducible instructions.
A task is complete when it works, is tested, documented, reviewed and reproducible by another person.
01 · Understand
Investigate the current implementation and requirements.
02 · Plan
Define the architecture, interfaces, risks and acceptance
criteria.
03 · Build and test
Implement and validate in code, simulation and, where
applicable, on physical hardware.
04 · Document and review
Make the result reproducible and complete the pull-request
process.
05 · Integrate and release
Prepare the completed work as part of OpenAMRobot 2.0.
The main engineering cycle is planned for approximately two months, followed where necessary by up to one additional month for physical testing, integration, documentation and release preparation.
Botshare Ltd is legally registered in Cyprus. Formal internship documents and recommendation letters will be issued by this entity.
The physical OpenAMRobot platform and workshop are located at MotionLab Berlin .
Review the engineering plan and send a concise, technically specific response showing how you understand and would approach the selected work.
Please refer to specific sections, workstreams or deliverables in the engineering plan where possible. You do not need to agree with the plan. If you believe something should be changed, simplified, removed or reprioritized, explain why.
A clear and honest 1-2 page proposal is more valuable than a long, generic or AI-generated response.
Join a focused engineering cycle as an intern, project collaborator or open-source contributor. Work on a real ROS 2 platform, produce visible results and help prepare OpenAMRobot 2.0.
We received around 80 applications with excellent CVs and cover letters, and we were genuinely impressed by the quality and diversity of the candidates. We decided to invite all applicants to Step 2.
We are excited to continue the communication and learn not only about your previous experience, but also how you think, what you would improve and where you believe you can contribute most effectively.
Navigation, Blockly, missions, robot monitoring and system information from a unified browser interface. Explore the UI repository →
Hugging Face shows how an open technology community can create visible, verifiable work and build lasting value. Open source does not guarantee success - but it gives contributors the opportunity to help shape a project from its early foundation.
OpenAMRobot is already gaining traction. A successful Release 2.0 will make the project more complete, valuable, visible and easier to adopt.
Read NVIDIA’s announcement →
Join the complete 2–3-month engineering cycle, work within a group and take ownership of an agreed area.
Deliver a defined technical work package with agreed interfaces, reviews, tests and documentation.
Contribute through GitHub at your own pace while following the same engineering, documentation and review standards.
The internship is our primary format. Project collaboration and open-source contribution are optional alternatives. All formats follow one shared plan and integrate into the same release.
The philosophy of this call is unpaid contribution. These opportunities are intended for people who see clear professional value in public portfolio work, real ROS 2 and robotics experience, visible GitHub contributions and international engineering collaboration.
At the same time, paid cooperation is possible for selected candidates - particularly senior or highly specialized contributors - where their expertise and skills match a concrete project need. In some cases, this may become relevant from the second month of cooperation. This is evaluated individually and is not a guaranteed outcome of participation.
Successful participation can create a real opportunity to continue with OpenAMRobot on a long-term basis. Depending on contribution, role, project needs and available resources, this may include ongoing paid or unpaid cooperation.
For contributors who become important to the project on a long-term basis, there may also be an opportunity to discuss participation in the project through an equity arrangement structured with a vesting and cliff mechanism. Depending on the role and circumstances, such long-term cooperation may be paid, contribution-based, or combine both approaches.
These possibilities are not promises of employment, compensation or equity. Any paid or equity-based cooperation would be discussed individually and formalized through a separate agreement.
Please participate only if you can realistically commit to the scope and schedule you propose. Once you accept a work package, you are expected to drive it to an agreed, tested and documented result. If circumstances change, communicate early and prepare a responsible handover.
We work documentation-first: understand the current system, define interfaces and acceptance criteria, build, test, review and document.
We value ownership, focused communication, independent research and constructive technical disagreement.
The robot and workshop are located at MotionLab Berlin . Remote contributors work with documented interfaces, simulation and reproducible environments. Hardware results are validated in the lab.
The current platform supports autonomous movement and automatic docking. Release 2.0 will strengthen integration, testing and release quality around these capabilities.
ROS 2 Jazzy, Nav2, SLAM/localization, Behavior Trees, route and zone configuration, docking, mission execution, recovery and integration testing.
OpenArm, URDF/xacro, MoveIt 2, ros2_control, grippers, drivers, Device Packages, manipulation APIs and contact/compliant motion.
LeRobot, teleoperation and demonstration capture, imitation learning, ACT, SmolVLA, dataset quality, policy evaluation, correction and deployment.
NVIDIA Jetson, Teensy/STM32, CAN/CAN-FD/CANopen, drivetrain, power and safety, sensors, wiring, mechanical integration and commissioning.
RGB/RGB-D cameras, calibration and synchronization, object perception and pose estimation, localization, sensor fusion and edge inference.
React, Flask, missions, operator and recovery UI, manipulation and training workflows, Blockly, structured voice commands, controls and diagnostics.
GitHub Actions, builds, linting, automated tests, simulation regression, containers, release artifacts, GitHub Pages, onboarding and reproducible instructions.
A task is complete when it works, is tested, documented, reviewed and reproducible by another person.
01 · Understand
Investigate the current implementation and requirements.
02 · Plan
Define the architecture, interfaces, risks and acceptance
criteria.
03 · Build and test
Implement and validate in code, simulation and, where
applicable, on physical hardware.
04 · Document and review
Make the result reproducible and complete the pull-request
process.
05 · Integrate and release
Prepare the completed work as part of OpenAMRobot 2.0.
The main engineering cycle is planned for approximately two months, followed where necessary by up to one additional month for physical testing, integration, documentation and release preparation.
Botshare Ltd is legally registered in Cyprus. Formal internship documents and recommendation letters will be issued by this entity.
The physical OpenAMRobot platform and workshop are located at MotionLab Berlin .
Review the engineering plan and send a concise, technically specific response showing how you understand and would approach the selected work.
Please refer to specific sections, workstreams or deliverables in the engineering plan where possible. You do not need to agree with the plan. If you believe something should be changed, simplified, removed or reprioritized, explain why.
A clear and honest 1-2 page proposal is more valuable than a long, generic or AI-generated response.