01 · Assemble
Build it on the bench
Base, lift, arms, sensors, wiring. Put the robot together and power it on.
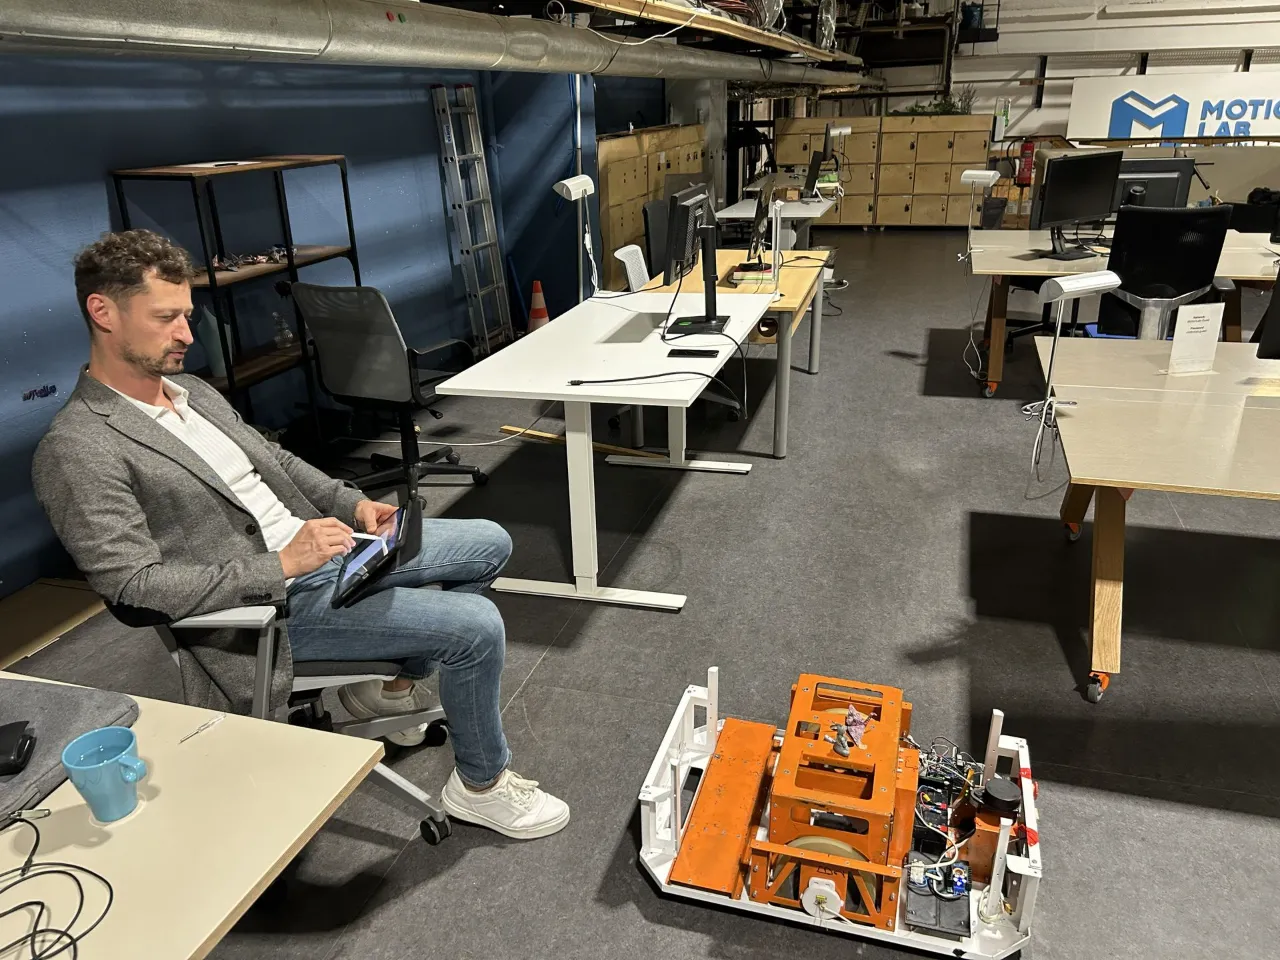
Early next year we run an Embodied AI hackathon. Until then, a small crew assembles OpenAMRobot 2.0 in our Berlin robotics lab and teaches it its first moves. First drive. First reach. First grasp.
We are looking for the people who want to be in the room when that happens.
OpenAMRobot 2.0 is a mobile base with a lift and two robotic arms, running ROS 2 and an Embodied AI layer on NVIDIA Jetson. The parts are here. The software is public. The plan is on the roadmap.
What it does not have yet: a crew that puts it all together and makes it move on the floor.
Base, lift, arms, sensors, wiring. Put the robot together and power it on.
Run our ROS 2 stack on the robot, find what breaks and fix it.
Motion planning and control for two arms on a moving, lifting base.
Teleoperation, demonstration capture, training and evaluating policies with LeRobot, ACT and SmolVLA.
Take what works in simulation and make it work in the physical world.
First drive, first reach, first grasp, first task. Then we hand the robot to the hackathon.
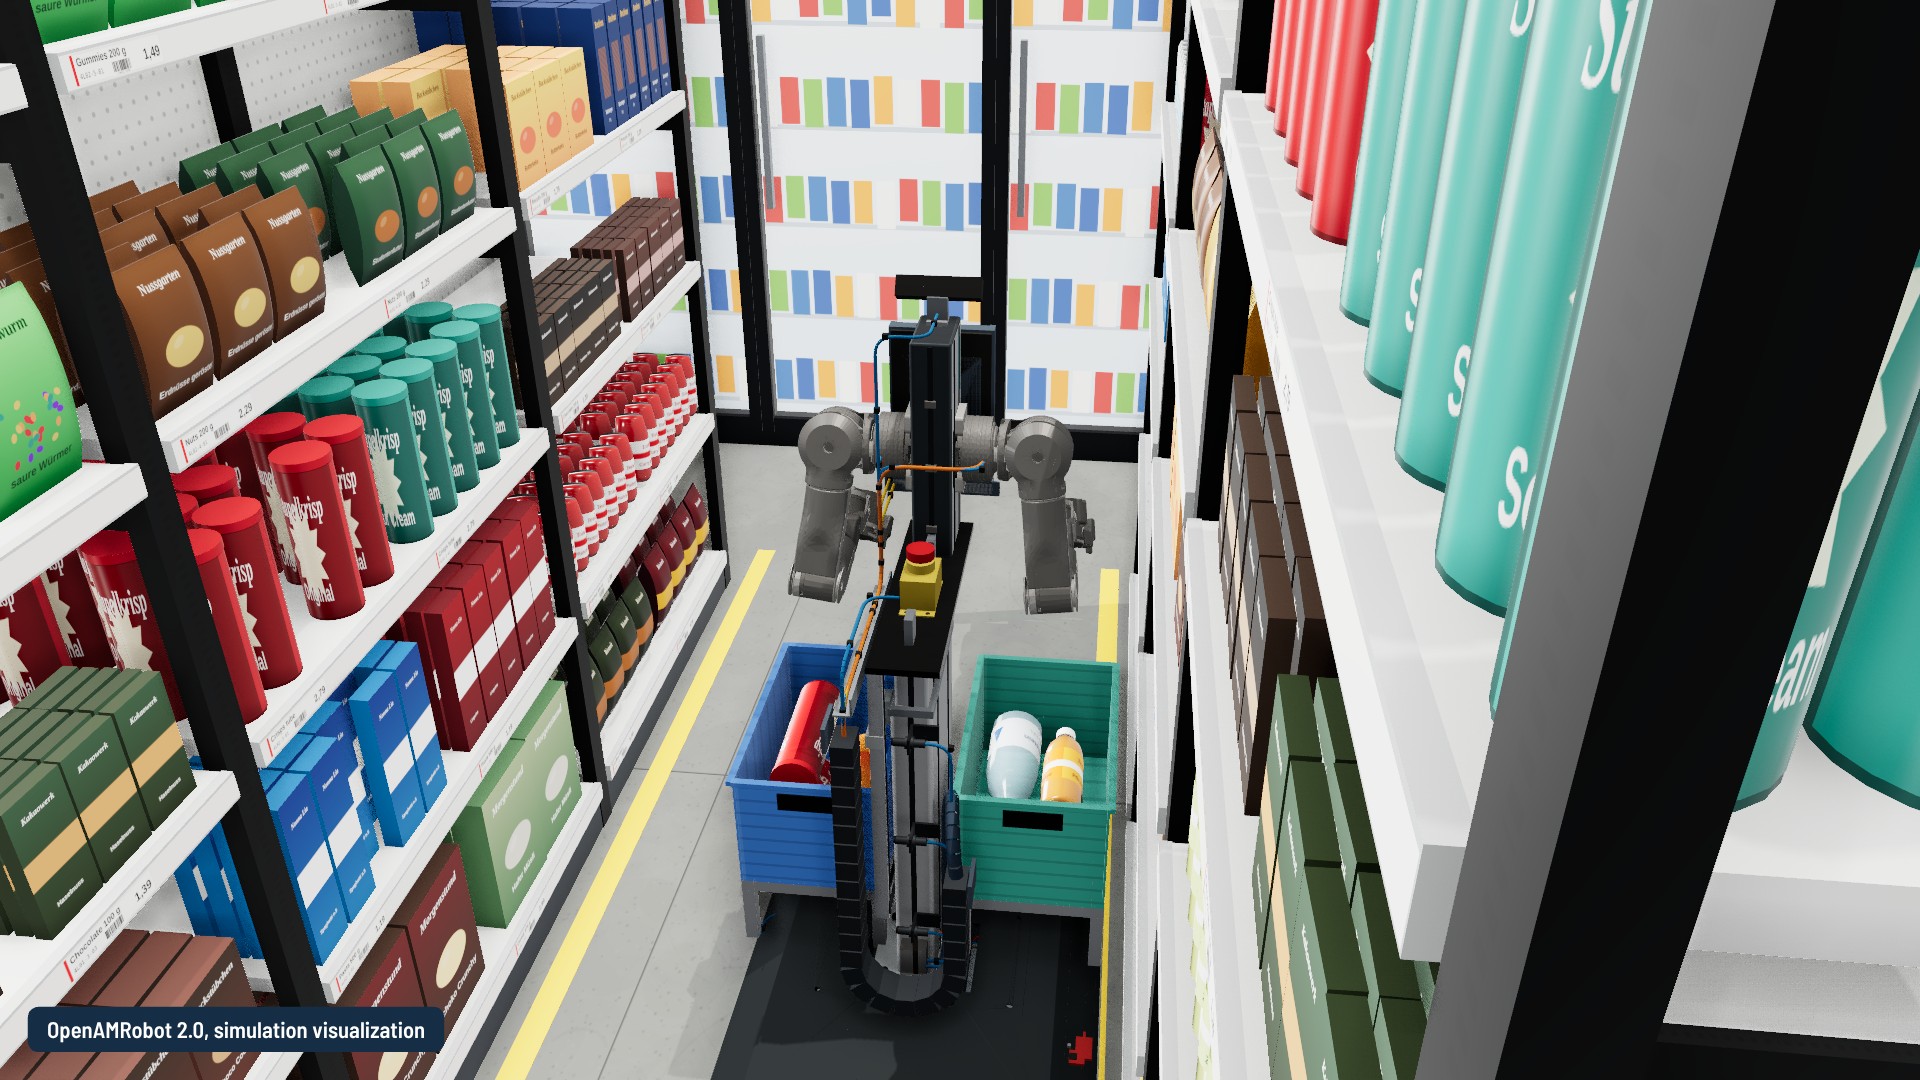
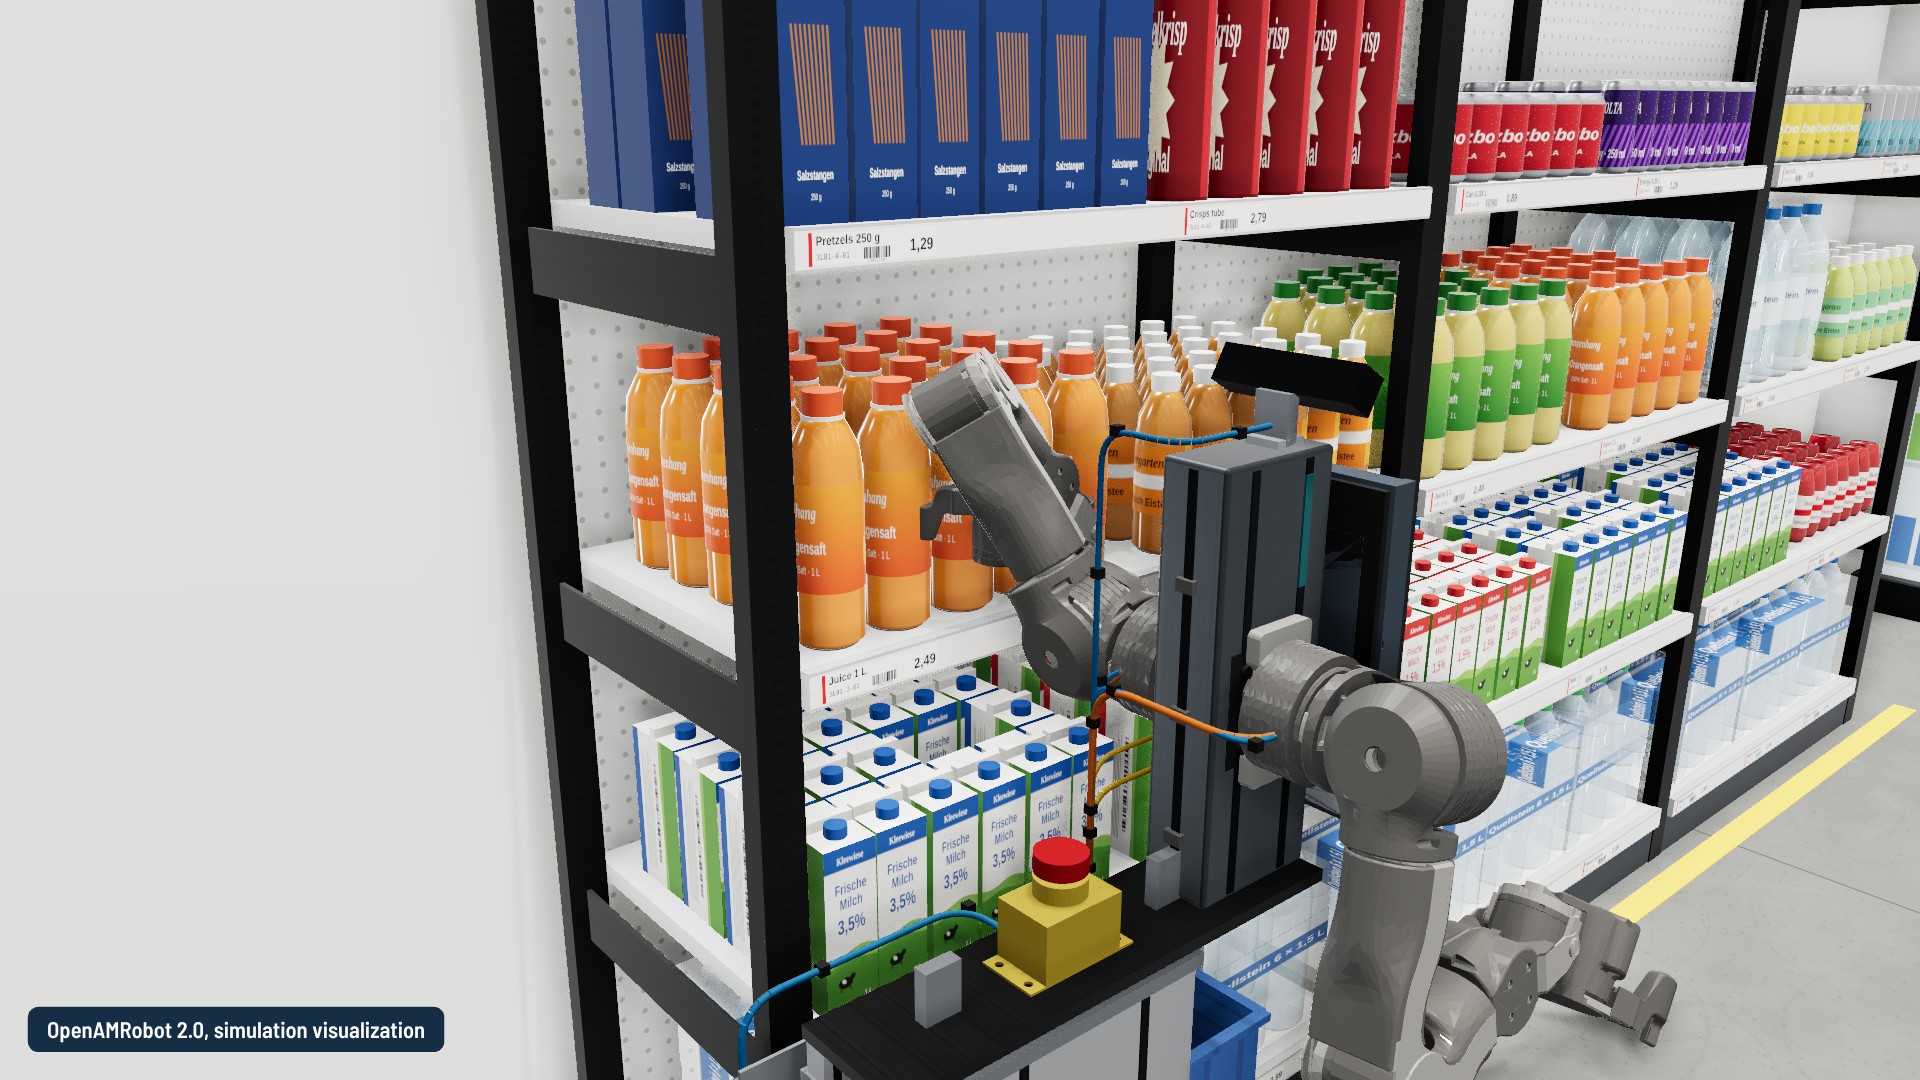
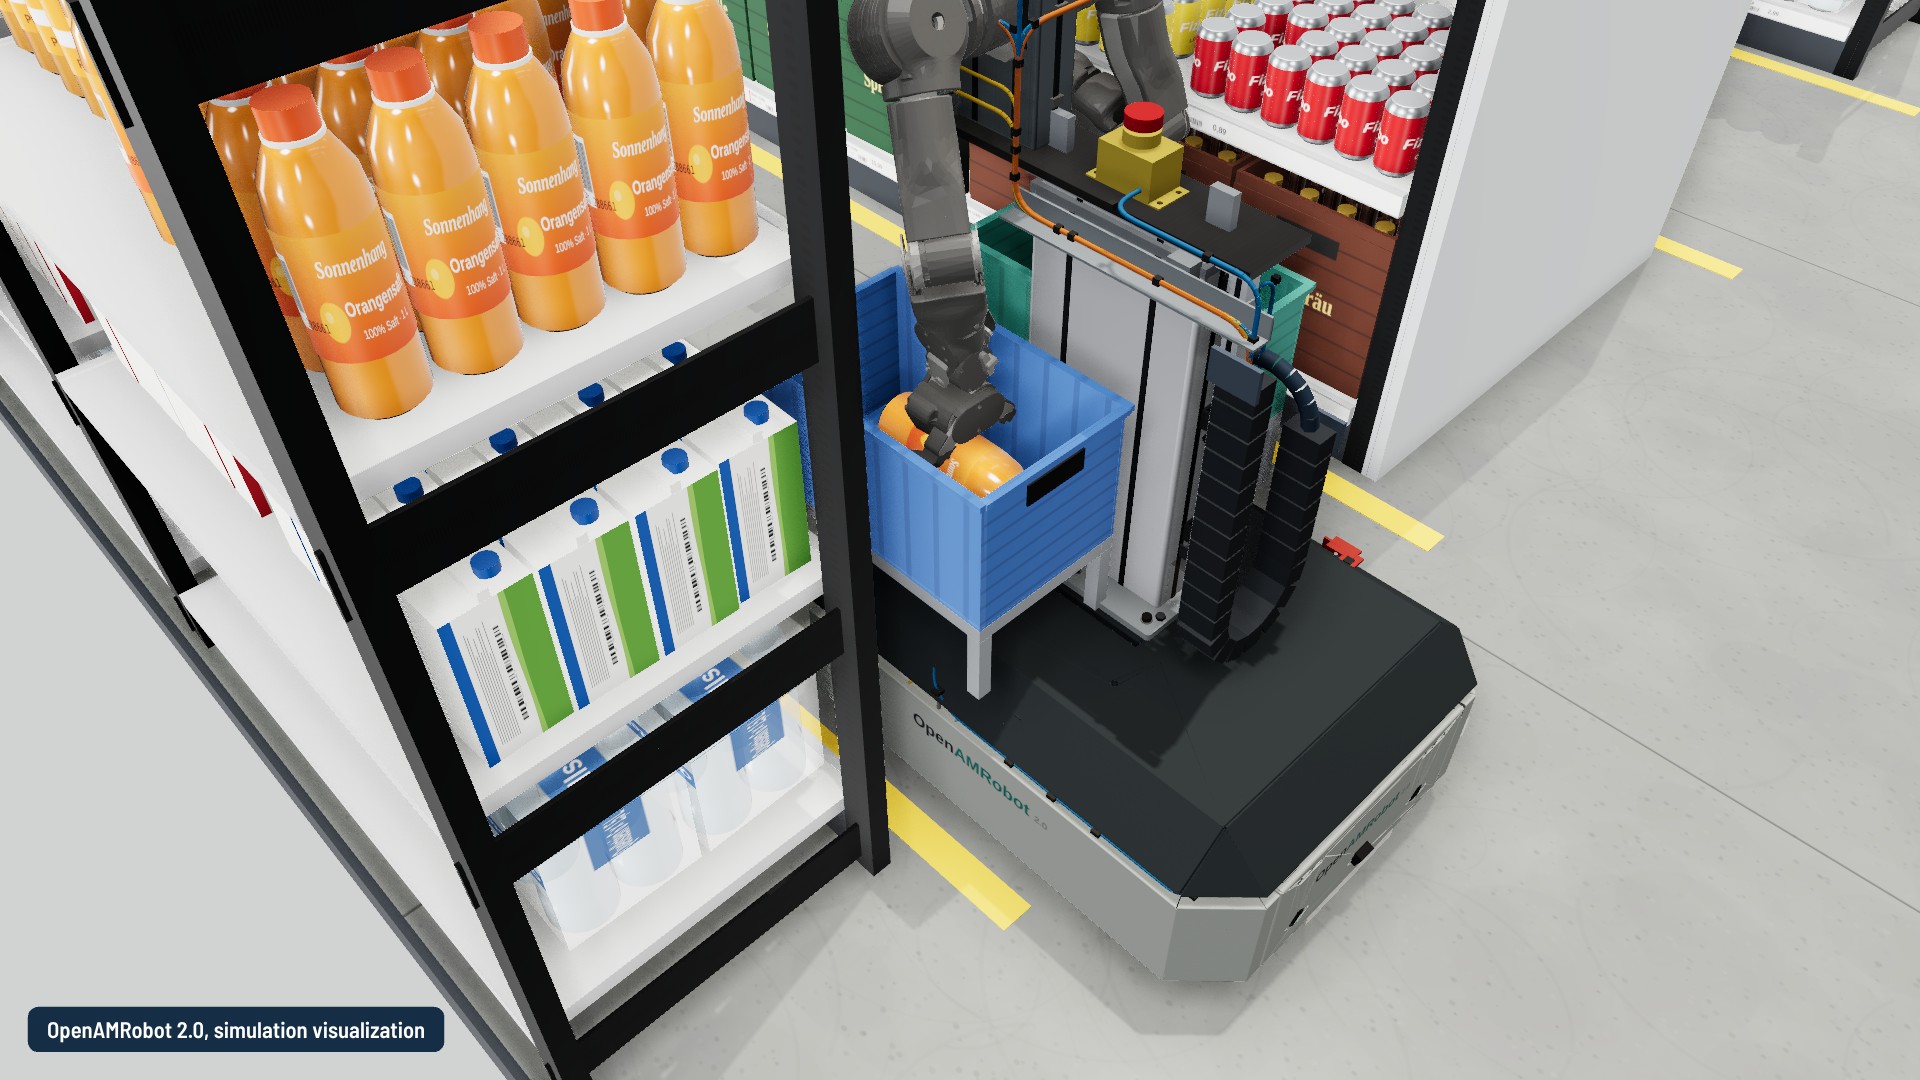
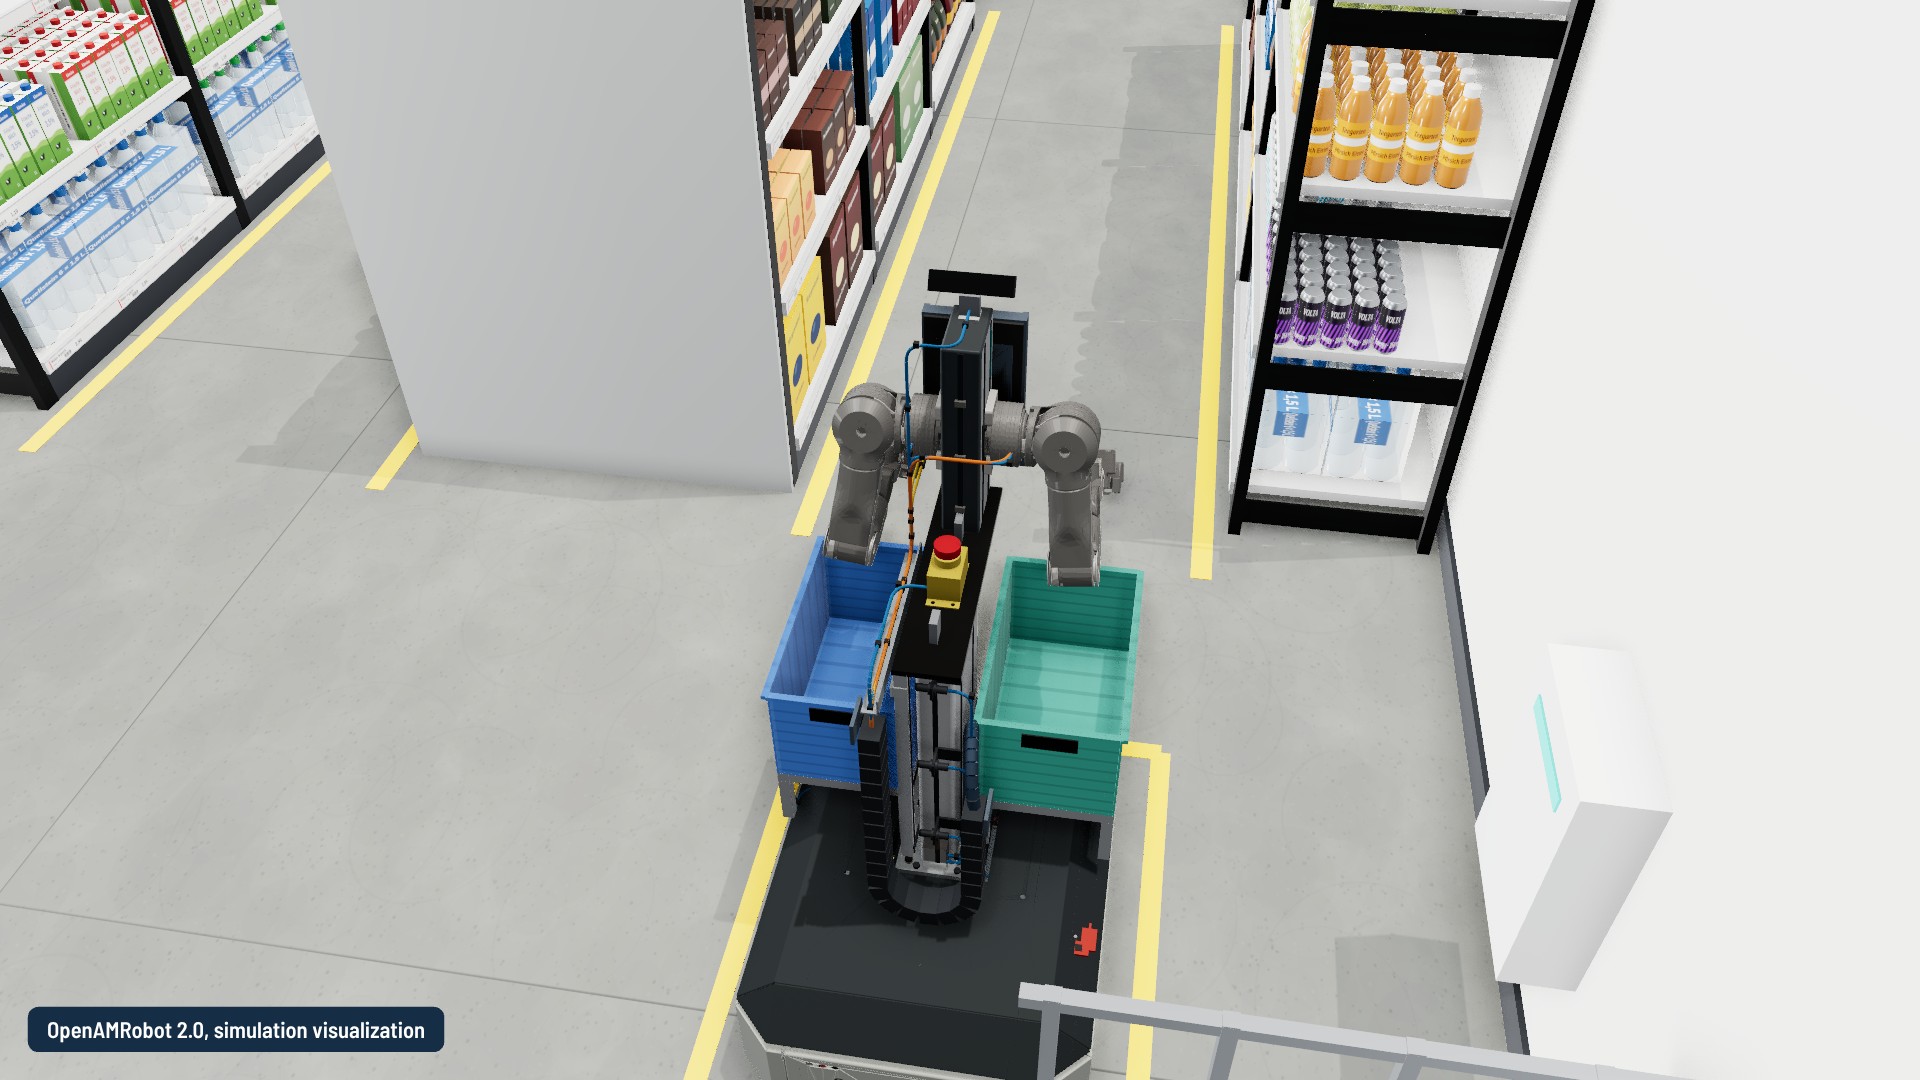
Drive the aisle, pick from a shelf, place into a tote, dock. Today these are simulation renders. In January they should be videos from the lab.
Hardware, electronics and mechatronics engineers who love to assemble, wire and debug. ROS 2 engineers. Embedded developers. Machine learning and robot learning folks. Ambitious students who have already built something with their own hands.
Motivated, curious and able to show up twice a week.
This is a voluntary crew, not a paid job.
What you get: your hands on an open-source dual-arm mobile manipulator, public GitHub contributions with your name on them, a front-row seat at the hackathon and a team that ships.
Early next year we run an Embodied AI hackathon. Until then, a small crew assembles OpenAMRobot 2.0 in our Berlin robotics lab and teaches it its first moves. First drive. First reach. First grasp.
We are looking for the people who want to be in the room when that happens.
OpenAMRobot 2.0 is a mobile base with a lift and two robotic arms, running ROS 2 and an Embodied AI layer on NVIDIA Jetson. The parts are here. The software is public. The plan is on the roadmap.
What it does not have yet: a crew that puts it all together and makes it move on the floor.
Base, lift, arms, sensors, wiring. Put the robot together and power it on.
Run our ROS 2 stack on the robot, find what breaks and fix it.
Motion planning and control for two arms on a moving, lifting base.
Teleoperation, demonstration capture, training and evaluating policies with LeRobot, ACT and SmolVLA.
Take what works in simulation and make it work in the physical world.
First drive, first reach, first grasp, first task. Then we hand the robot to the hackathon.
Drive the aisle, pick from a shelf, place into a tote, dock. Today these are simulation renders. In January they should be videos from the lab.
Hardware, electronics and mechatronics engineers who love to assemble, wire and debug. ROS 2 engineers. Embedded developers. Machine learning and robot learning folks. Ambitious students who have already built something with their own hands.
Motivated, curious and able to show up twice a week.
This is a voluntary crew, not a paid job.
What you get: your hands on an open-source dual-arm mobile manipulator, public GitHub contributions with your name on them, a front-row seat at the hackathon and a team that ships.
APPLY
Send your profile or portfolio (a CV works too) and tell us why you want in. We read every answer, so make it count.